---
title: "LumiScan VGR"
description: "LumiScan VGR: 3D vision-guided robotics for bin picking and assembly. Point clouds, part poses, grip points and collision-free paths, with PLC via PROFINET."
product: "LumiScan VGR"
component: "lumiscan-vgr"
version: "1.8.4"
display_version: "1.8.4.6"
latest_version: true
language: "en"
url: "https://docs.hdvisionsystems.com/en/lumiscan-vgr/1.8.4/index.html"
---
# LumiScan VGR
| | | |
| --- | --- | --- |
| 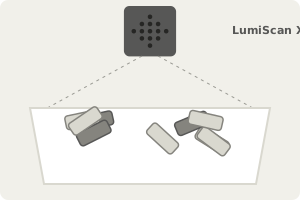
**Capture the bin in 3D.** LumiScan X builds a point cloud of the parts. | 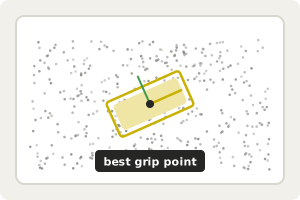
**Find the parts and the best grip.** Pose of each object, grip points and a collision-free path. | 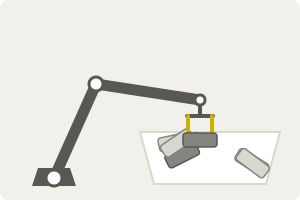
**The robot picks.** The PLC gets the best grip point over PROFINET or OPC UA. |
LumiScan VGR is vision-guided robotics software for bin picking and automated assembly. It builds point clouds from the LumiScan X 3D camera, localizes the parts by matching 3D models or with machine learning for complex scenes, computes grip points and plans a collision-free path for the robot. The PLC controls each step and receives the best grip point over PROFINET or OPC UA.
For licensing, see [Licence](https://docs.hdvisionsystems.com/en/lumiscan-vgr/1.8.4/system-requirements.html#licence). Questions or an error message? See the [FAQ](https://docs.hdvisionsystems.com/en/lumiscan-vgr/1.8.4/faq.html).